 Max Pacheco
Trial on 3D Gaussian Splatting for Emulating Real-Life Learning Experiences in Undergraduate Educational Robotics
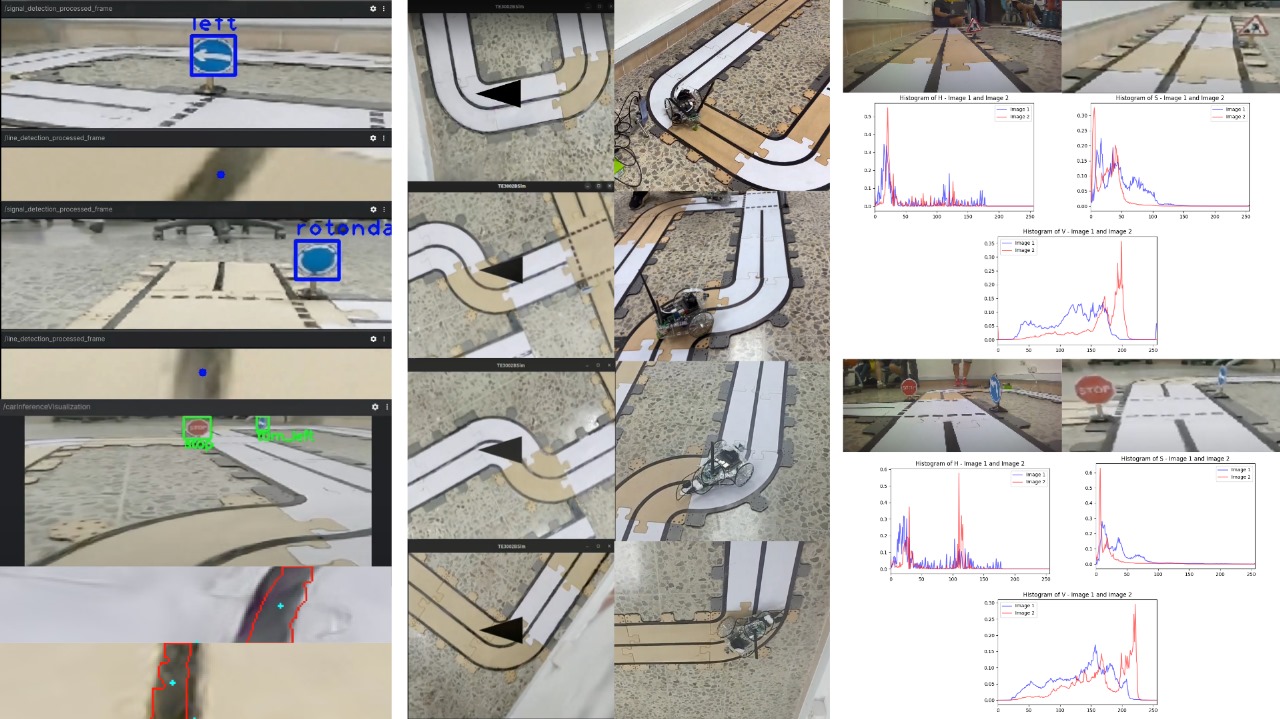
Following the Puzzlebot’s project, one of my professors invited me to collaborate with him and other students of him on a simulator created from a novel rendering technique called Gaussian Splatting, which outperforms common popular photogrammetry techniques in terms of time for processing, and photorealism. The purpose of this project was to generate a photorealistic map of the track used for the Puzzlebot’s project and place a camera on the map simulating what the actual car saw, and test the vehicle’s performance with minimal intervention. The simulator run in Unity would output an image (simulating the camera), and would receive the vehicle’s twist command (linear and angular velocities), and would then update the resulting image from said command, just like in real life.
I adapted the code from my team and from another team to meet the compatibility requirements (like topic types or names), and other minimal changes like controller parameters (because the simulator’s dynamics didn’t have the same dynamics of the real robot), and recorded the rosbags and screen recordings for testing.
Finally, we submitted our work and the extended abstract got accepted for the ICRA@40 Conference in Rotterdam, NL.